
SIEMIENS 1FK6 series three-phase servo motor
SIEMIENS 1FK6 series three-phase servo motor
Core positioning and basic information
Safety Regulations: Core Risks and Protection Requirements
Safe operation is the primary focus emphasized in the document, and multiple types of risks and mandatory protective measures have been identified based on the characteristics of the motor
(1) Electrical safety risks
Voltage hazard: When the motor rotor rotates, the terminal voltage can reach up to 300V, and direct contact can cause electric shock accidents.
Operating standards:
All electrical operations must be carried out after the motor has completely stopped, and only certified electricians are allowed to operate;
Strictly follow the EN 50110-1 (DIN VDE 0105-100) standard, and before operation, follow the five step process of "power-off - isolation - electrical testing - grounding short circuit - shielding adjacent live parts";
Unauthorized modification of electrical circuits or shielding layers is prohibited to avoid short circuits or electromagnetic interference.
(2) Permanent magnet safety risks
Magnetic field hazard: The motor rotor is equipped with high magnetic flux density permanent magnets, which have strong attraction to ferromagnetic objects and can interfere with pacemakers and damage electronic data carriers (such as hard drives, USB drives, magnetic cards).
Protective measures:
It is explicitly prohibited for users of pacemakers to enter the motor disassembly area, and conspicuous signs must be posted on site;
Electronic data carriers should be kept away from the motor (especially the disassembled rotor), with a minimum safe distance of no less than 1m;
During transportation or storage, avoid close contact between the motor and ferromagnetic objects such as iron tools and steel to prevent component damage caused by adsorption and collision.
(3) Thermal safety risk
High temperature hazards: The surface temperature of the motor during operation can reach up to 140 ℃. Direct contact can cause burns, and high temperatures may damage adjacent temperature sensitive components such as wires and electronic components.
Protection requirements:
Do not touch the high-temperature surface of the motor, and install anti touch and anti protective covers if necessary;
Temperature sensitive components should be kept away from the surface of the motor to avoid direct contact;
Ensure the effective operation of the motor temperature control device to prevent damage to windings and bearings due to overheating, or demagnetization of permanent magnets.
(4) Environmental and installation safety restrictions
Prohibit the use of motors in explosion-proof areas (unless specially certified by Siemens);
During the installation, transportation, and maintenance of the motor, it is necessary to avoid severe impacts to prevent permanent magnet displacement or winding damage;
The maximum weight of the motor is 50kg, and lifting devices that comply with Appendix I of the 98/37/EEC Machinery Directive (such as lifting rings and slings) must be used for handling. It is prohibited for a single person to handle in violation of regulations.
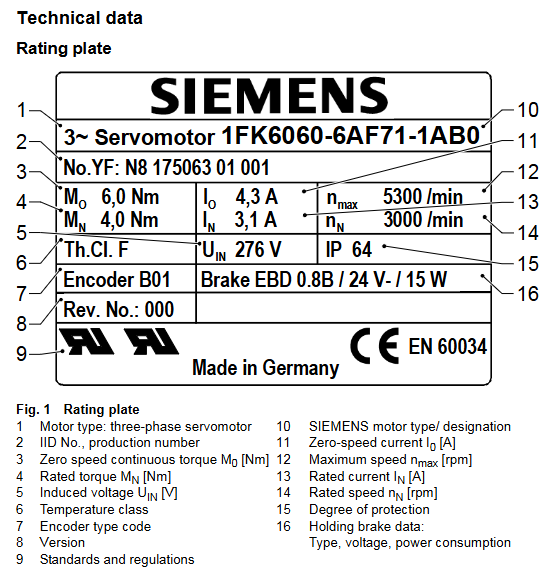
Product Core Information: Attributes, Applications, and Delivery
(1) Core attributes of the product
The 1FK6 series motor is a permanent magnet excitation three-phase synchronous servo motor, with a core design adapted to the "sine current principle motor control pulse inverter". Precise control of speed and torque needs to be achieved through a frequency converter, and direct connection to the three-phase power grid is prohibited (otherwise it will cause winding burnout and permanent magnet demagnetization). The motor adopts self cooling method, compact structure, suitable for high-precision driving and positioning scenarios, and has the characteristics of low noise, long life, and high protection level (IP64).
(2) Typical application scenarios
Mainly used for equipment with strict requirements for driving accuracy and response speed, including:
Machine tools (cutting, machining centers);
Automated production equipment;
Industrial robot;
Material handling devices (such as conveyors, robotic arms).
(3) Delivery scope and acceptance requirements
Delivery list: motor body (including integrated encoder, optional brake), separate product nameplate (to be attached near the equipment for reference), multilingual manual;
Acceptance criteria:
After receiving the goods, it is necessary to immediately verify the waybill with the physical object to confirm that there are no missing parts or transportation damage;
If any transportation damage is found, it is necessary to immediately claim compensation from the carrier; If there are component defects or incomplete deliveries, it is necessary to promptly contact the responsible representative of Siemens;
The instruction manual should be properly stored in an easily accessible location near the equipment for easy operation and maintenance reference.
Key technical parameters: performance and adaptation indicators
(1) Infrastructure and protection parameters
Parameter category specific indicator standard basis
Installation form standard IM B5, optional IM V1, IM V3 EN 60034-7
Protection level IP64 (dustproof, splash proof), optional IP65 (enhanced dustproof and waterproof), drive end flange can be upgraded to IP67 EN 60034-5
Cooling method: self cooling (no additional cooling device required) EN 60034-6
Design standard for shaft end: keyway free cylindrical shaft (tolerance k6); Optional: with keyway+key (tolerance k6, half key balance) DIN 748-3, IEC 60072-1
(2) Electrical and Performance Parameters
Parameter category specific indicator standard basis
Insulation class F (maximum allowable operating temperature 155 ℃) EN 60034-1
Braking parameters: normally closed holding brake (optional), power supply voltage 24V DC ± 10%, power 15W DIN VDE 0580
Speed range: Rated speed (nN) ≤ 3000rpm, maximum speed (nmax) ≤ 5300rpm, as indicated on the product nameplate
Torque parameters: Zero speed continuous torque (M0) up to 6.0Nm, rated torque (MN) up to 4.0Nm, as indicated on the product nameplate
Current parameters: Rated current (IN) up to 4.3A, zero speed current (I0) up to 3.1A, as indicated on the product nameplate
Noise level 1FK6 03./04.: ≈ 55dB (A); 1FK6 06.:≈65dB (A); 1FK6 08./10.: ≈ 70dB (A) (below 3000rpm) EN 60034-9
(3) Environmental and lifespan parameters
Parameter category specific indicator standard basis
Environmental temperature operation: -15 ℃~+40 ℃; Exceeding the range requires derating (power factor 0.92 at 50 ℃, power factor 0.82 at 60 ℃) EN 60034-1
Altitude adaptation ≤ 1000m (standard); 2000m power factor 0.942500m power factor 0.9 EN 60034-1
Bearing lifespan Rolling bearings (lifetime lubrication), reference lifespan 20000h Siemens design specifications
Radial shaft seal lifespan of approximately 5000 hours under oil lubrication conditions according to Siemens design specifications
Vibration tolerance vibration acceleration ≤ 5g, vibration level N EN 60034-14
(4) Optional configuration parameters
Encoder system: incremental encoder (sin/cos 1VPP), absolute encoder (EnDat protocol), simple absolute encoder, rotary transformer;
Additional components: planetary gearbox, normally closed holding brake;
Protection upgrade: IP65 protection level, IP67 protection for drive end flange.
Installation and Connection: Specifications and Key Requirements
(1) Transportation and Storage Standards
Transportation requirements:
Use appropriate lifting devices (such as slings and rings) to avoid tying the motor shaft or flange directly with ropes and prevent damage to components;
During transportation, it is necessary to fix it firmly, avoid severe bumps or impacts, and prevent the permanent magnet from shifting;
Comply with local transportation regulations, clarify that the motor is a "strong magnet containing equipment", and avoid magnetic interference issues during air transportation.
Storage conditions:
The storage environment needs to be dry, low dust, and low vibration (effective vibration speed)v eff<0.2mm/s);Avoid direct sunlight or high temperature and humidity environments to prevent the winding from getting damp or the performance of the permanent magnet from deteriorating;
Before storage, remove the rust inhibitor at the shaft end (using commercial solvents) to avoid affecting subsequent installation.
(2) Mechanical installation requirements
Installation gap: At least three sides of the motor need to reserve a 100mm heat dissipation gap to ensure self cooling effect;
Fixed specifications:
Use hexagon socket head screws with a strength grade of ≥ 8.8 to fix the flange, and tighten them evenly (to avoid flange deformation);
The screw torque must meet the equipment requirements, and excessive tightening is prohibited to cause thread damage;
Load limit:
Motors with integrated brakes are prohibited from bearing axial forces, and radial forces must strictly follow the requirements of the project planning guidelines;
When installing vertically (with the shaft end facing upwards), protective measures should be taken to prevent liquid from seeping into the upper bearing;
Balance requirements:
Motors with keyways are already balanced with half keys when they leave the factory. After installing output components such as couplings and gears, they need to be rebalanced according to ISO 1940 standards;
Do not strike the motor shaft or bearings. Special tools (such as a puller) should be used to install/remove the output components. If necessary, the output components can be heated (to avoid high temperature conduction to the inside of the motor).
(3) Electrical Connection Specification
Cable selection:
Pre assembled shielded cables recommended by Siemens must be used (not within the scope of delivery), and power cables and signal cables must be laid separately to avoid electromagnetic interference;
The cable should be compatible with the rated voltage and current of the motor, and have sufficient mechanical strength to avoid pulling and damaging it;
Plug connection:
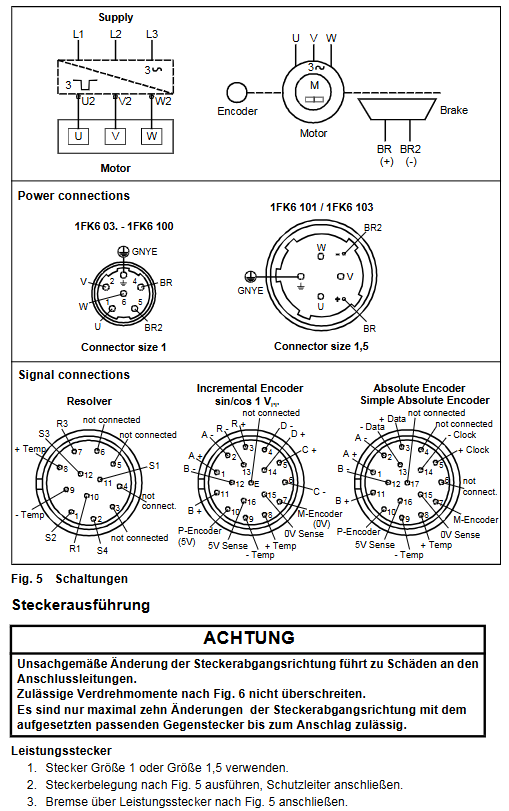
The plug types are divided into power plug (P) and signal plug (S), and the wiring must strictly follow the drawing (Fig.5), and misconnection is prohibited;
The plug torque must comply with the specifications (power plug: 12Nm/20Nm, signal plug: 12Nm), and excessive twisting is prohibited;
The direction of the plug can be adjusted up to 10 times (when equipped with a matching socket) to avoid cable fatigue damage;
The inside of the plug should be clean and free of residue and moisture, and the sealing surface should be intact to ensure an IP64 protection level;
Grounding and shielding:
The protective conductor (PE) must be reliably grounded, and the grounding resistance must comply with local electrical regulations;
The cable shielding layer needs to be grounded at both ends to reduce high-frequency harmonic radiation and avoid electromagnetic interference (EMC);
Special requirements:
The encoder and temperature sensor are electrostatic sensitive components, and touching their connection terminals with hands or tools with static electricity is prohibited;
The temperature sensor can only cope with conventional overheating scenarios, and an additional thermal overload relay needs to be configured when the motor is stationary and overloaded.
Start up, operation and maintenance, and troubleshooting
(1) Pre startup inspection
Electrical connection inspection: Confirm that all plugs are securely fastened, the wiring is correct, and there are no loose or short circuit hazards;
Mechanical state inspection: manually rotate the motor output component to confirm that there is no jamming or friction noise, and that the keyway (if any) is fixed;
Protection device inspection: Motor overload protection, temperature protection and other devices have been activated and function normally;
Environmental condition inspection: The installation environment temperature and altitude meet the requirements, and the heat dissipation gap is sufficient;
Auxiliary equipment inspection: The supporting equipment such as frequency converter and encoder have been debugged and the parameters are adapted to the characteristics of the motor.
(2) Start the process
Brake test (with brake motor): Apply 24V DC ± 10% voltage to brake pins BR and BR2 to confirm that the rotor can rotate freely without friction noise;
Inverter startup: Start the system according to the instructions of the inverter (such as SIMODRIVE, MASTERDRIVES MC), and the initial speed should be lower than the rated speed;
Operation monitoring: Observe the operation status of the motor, confirm that the speed and torque meet the requirements, and there is no abnormal vibration, noise, or overheating;
Positioning test (positioning scenario): Verify that the encoder signal is normal and the motor positioning accuracy meets the standard;
Emergency stop test: Trigger the emergency stop button, confirm that the brake and frequency converter are linked normally, and the motor can quickly stop.
(3) Daily maintenance and cycle requirements
Cleaning and maintenance: Regularly clean the dust and oil stains on the surface of the motor to ensure effective heat dissipation. Power off during cleaning to prevent water or cleaning agents from seeping into the interior of the motor;
Status check:
Regularly inspect cables and plugs for damage, aging, and loose fasteners;
Monitor the operating temperature, vibration, and noise of the motor, and promptly shut down for troubleshooting if any abnormalities are found;
Periodic maintenance reference:
Bearing: The reference life is 20000 hours. If there is abnormal noise or increased vibration during operation, it should be replaced in a timely manner;
Radial shaft seal (oil lubrication): with a reference life of 5000 hours, regularly check for leaks and replace if necessary;
Special maintenance: After disassembling the motor, the encoder system must be recalibrated, otherwise it will affect the positioning accuracy.
(4) Common faults and solutions
Core causes of fault phenomena and solutions
Irregular motor operation: 1. Insufficient shielding of motor/encoder cables, electromagnetic interference; 2. The gain of the frequency converter controller is too high. 1. Check if the grounding of the cable shielding layer is reliable; 2. Reduce the controller gain according to the frequency converter manual
Severe motor vibration: 1. Coupling/load imbalance; 2. Poor alignment of the drive chain; 3. Loose fixing screws. 1. Rebalance the load and coupling components; 2. Calibrate the coaxiality of the drive chain; 3. Check and tighten all fasteners
Abnormal operating noise (abnormal noise): 1. Foreign objects enter the interior of the motor; 2. Bearing wear or damage; 3. Permanent magnet displacement: 1. Stop the machine for inspection and remove foreign objects; 2. Replace the bearings; 3. Contact Siemens for professional maintenance
Motor overheating (surface temperature>140 ℃) 1. Load exceeding rated torque; 2. Insufficient heat dissipation gap or surface dust; 3. Temperature sensor malfunction: 1. Reduce the load to the rated range; 2. Clean the surface dust and increase the heat dissipation gap; 3. Repair or replace the temperature sensor
Encoder signal abnormality: 1. Encoder wiring error; 2. The encoder is subject to electromagnetic interference; 3. The encoder is damaged. 1. Check the wiring diagram and rewire it; 2. Strengthen cable shielding and grounding; 3. Replace the encoder and calibrate it
(5) Equipment Disposal Standards
When the motor is scrapped, it should be classified and recycled according to national/local regulations, or returned to Siemens for disposal. It is prohibited to dispose of it at will;
Encoders, brakes, and other electronic components need to be disposed of separately as electronic waste to avoid environmental pollution;
Before disposal, it is necessary to remove the permanent magnets inside the motor (operated by professionals) to prevent strong magnetic fields from causing harm to disposal personnel or equipment.
- OMRON
- ABB
- General Electric
- EMERSON
- Honeywell
- HIMA
- ALSTOM
- Rolls-Royce
- MOTOROLA
- Rockwell
- Siemens
- Woodward
- YOKOGAWA
- FOXBORO
- KOLLMORGEN
- MOOG
- KB
- YAMAHA
- BENDER
- TEKTRONIX
- Westinghouse
- AMAT
- AB
- XYCOM
- Yaskawa
- B&R
- Schneider
- KONGSBERG
- NI
- WATLOW
- ProSoft
- SEW
- ADVANCED
- Reliance
- TRICONEX
- METSO
- MAN
- Advantest
- STUDER
- DANAHER MOTION
- Bently
- Galil
- EATON
- MOLEX
- DEIF
- B&W
- ZYGO
- Aerotech
- DANFOSS
- Beijer
- Moxa
- Rexroth
- Johnson
- WAGO
- TOSHIBA
- BMCM
- SMC
- HITACHI
- HIRSCHMANN
- Application field
- XP POWER
- CTI
- TRICON
- STOBER
- Thinklogical
- Horner Automation
- Meggitt
- Fanuc
- Baldor
- SHINKAWA
- Other Brands
- UniOP
- KUKA
- Iba
- Beckhoff
- ADLINK
-
 LTi LSH-074-2-30-320/T1 1R Servo Motor
-
 LTi DRiVES LSP08-028-320-30-BPH2MY17E0803 Servo Motor
-
 LUST LTI SO24.007.0020.0000.1 Servo Controller
-
 LTI CDE34.017.W3.0 Frequency Inverter
-
 LUST LTi DRIVES LSH-097-0960-30-560/T1 Servomotor
-
 LTi DRiVES LSP10-056-560-50-00H1MY 1M0 Servomotor
-
 LTi DRiVES LSP08-028-320-55-00H1MY 170 Servomotor
-
 LTI MC6432 C1 D3 S12 G20 Servo Drive
-
 Keba LTi CDE32.008 C3.0 Frequency Inverter
-
 Lust LTI CDE32.004 C2.4 V4.10-02 Servo Controller
-
 LTI SO CM-P.0122.2015.1 Servo Drive
-
LUST LTi LST-127-2-30-560/T1 Servomotor
-
 LTI VF1402S Drive
-
LUST LTi LSH-074-3-45-560/T1 Servomotor
-
 LUST LTi CDB32.004 C2.4.SH Servo Drive
-
 LTI SO82.004.0030.0000.2 Servo Drive
-
 LTi Drives CDD34.008 W2.1 BR Servo Driver
-
 Lust LTI CDE32.004 C2.4 Servo Controller
-
 LTi Drives DSM4-14.2-21R83-200 Servo Motor
-
LTI CDB32.004 C2.4 SH V4.00-3 Servo Drive
-
 LUST LTi Drives CDA34.017 W1.4 BR B0 Servo Drive
-
 LTI Drives MS100 0927.0017 Mounting Set
-
 LTi REENERGY E230 G360 Frequency Inverter Controller
-
 LTI Drives Netzfilter 090.01.540.UR Mains Filter
-
LTI Drives LSP08-035-320-30-B0R1PY170 Servo Motor
-
 LUST LTi Drives CDS44.072LC1.2 Servo Drive
-
 LTI Drives BR-090.03.540.UR.H38 Braking Resistor
-
 LTi Drives PM-E40.2DRA054P Pitch Control Inverter
-
LTI Drives LSN-097-0960-30-0560/T1 S4 B Servo Motor
-
LUST LTI SO24.002.0020.0000.1 Servo One Junior
-
 LTI MOTION SO84.032.0003.0001.2 Servo Drive
-
 LTI 330-0919 IBOP Actuator Cylinder
-
 LTI CDE32.004 C2.4 Servo Drive
-
 LUST LTI CDD34.017 W3.4PC1 Servo Drive
-
 LTI CDA3208 C3.0 HF AC Servo Drive
-
LTi LSP08-028-560-55-00H1MY170 Servo Motor
-
LUST LTI LSH-074-3-30-560/T1 G6.1S Servo Motor
-
LTi CDA32.006 C3.0 H09 Servo Drive
-
LTI SO22.003.0010.0000.0 Servo One Junior Drive
-
LTi DSM4-14.2-21R83-200 Servo Motor
-
 LTi Tools 1237 7 Piece Flip Socket Set
-
 LTi CDE34.008.W2.4 Servo Drive
-
 LUST SO84.008.1020.0070.1 ServoOne Drive
-
LTi LSP06-015-320-30-00H1MY170 Component
-
LTi LSP08-028-320-55-B0H1MY17W Servo Motor
-
 LTi SO84.032.0173.0100.1 Servo Drive
-
LTi CDB34.006.W3.0.PC1.H39 Servo Drive
-
 LUST BR-200.02.540.UR Brake Resistor
-
LTi REENERGY E230 G360 Frequency Inverter
-
 LTi BR-026.03.540-UR Brake Resistor
-
 LUST CDA32.006.C3.0.H09 Frequency Inverter
-
 LTi SO84.016.1030.0000.0 ServoOne Drive
-
LTi SO24-004-0030-1000-0 Servo Controller
-
LUST CDE34.010.D2.4 Positioning Controller
-
LTi SO22.003.0080.0000.0 Servo Controller
-
 LUST CDB32.004.C2.4.SH Servo Drive
-
LTi LSP06-015-320-60-B0H1MY170 Unit
-
LTi Motion PM-D35.1WVA02 Module
-
 LTi BR-090.03.540.UR.H38 Brake Resistor
-
LTi FGP 111/002-25 AA Servo Motor
-
 LTi ServoOne Junior SO22.006 Servo Controller
-
 LUST CDA34.008.W1.4.BR Drive Controller
-
LUST CDA34.017.W3.0 Drive System
-
LUST CDE32.004.C2.4 Drive Controller
-
LTI CDE32.004.C3.0 Servo Drive
-
LUST LSH-097-2-30-560 Servo Motor
-
 LUST CDB32.003.C2.4 Servo Controller
-
 LUST CDB32.003.C2.3 Servo Controller
-
LUST CDA34.017.W3.0 Drive Controller
-
 LTI Tools LT-1400Q Torque Extension
-
 LUST SO82.004.0030.0060.2 Servo Drive
-
LUST CDA32.006.C3.0.H09 Drive Controller
-
LTI CDB32.004.C3.7.SH Servo Drive
-
LTI LSH-127-3-30-560 Servo Motor
-
LUST CDA34.017.C2 Servo Drive
-
LTI CM-DPV1 3.0 V2.25-00 Module
-
 LTI CDE34.005 W2.4 Servo Drive Controller
-
 LUST LR32.8 0925.0018 Line Choke
-
LUST LTi CM-DPV1 3.0 Communication Module
-
LUST LTI Drives CCD34.024.W2.1.BR Servo Drive
-
Lust LTi Drives CDE32.008.W2.2.BR Positioning Controller
-
LTi DRiVES LSH-050-3-45-320/T1 Servo Motor
-
LUST LTI Drives CDA34.006.W1.5.BR Inverter
-
LUST LTI DRIVES VF1204S Frequency Inverter
-
 Lust LTI Drives EMC100.1 Network Filter
-
LUST LTi DRIVES LSH-097-1-30-560/T1 Servo Motor
-
LTi Drives Lust CDA34.017.W3.0 Servo Controller
-
 LUST LTI DRIVES CDE32.003 Frequency Inverter
-
LUST CDB34.003.C2.0.H15 Servo Drive Positioning Controller
-
 LTi DRiVES SO84.076.S030.0001.2-W Servo Drive
-
 LUST LTI Drives CDE32.003 Frequency Inverter
-
 LUST LTI Drives CDA34.017.C2.CP Servo Controller
-
LTI Motion CDE32.004.C2.4 Servo Drive
-
LUST LTI DRIVES CDE34.017.W2.0.H18 Inverter
-
 LUST LTI Drives BR-200.02.540.UR Braking Resistor
-
 LTi DRiVES LR32.8 Line Reactor
-
Lust LTI Drives CDS44.032 Inverter
-
LUST LTI DRIVES CDB34.008 W2.4 Frequency Converter
-
LTI DRIVES SO84.012.1030.0000.2 Servo Drive
-
 LTI SO84.024.1030.0011.2 Servo Drive Controller
-
 LTi Drives SO84.076.S030.0001.2-W 52.5 kW Controller
-
LTi LUST SO84.012.1030.0000.2 Servo Drive Controller
-
LTI Drives SO84.008.0020.1070.1 Servo Controller
-
LTI Motion CDE32.004.C3.0 Positioning Controller 1.6 kVA
-
LUST LTi Drives CDB34.010C2.4 Servo Drive Controller
-
Lust LTi Drives CDD32.003.C2.0 Servo Controller
-
 Lust LTi Drives CDB32.003C2.3 Servo Controller UM-8I40
-
 LTi Drives SO CM-1.0003.110C.0 Control Module
-
 LTI Drives GmbH LR34.44-UR Servo Drive Unit
-
LTI DRIVES VF1202S Frequency Inverter
-
 LTi ServoOne Junior SO24.004 Servo Drive
-
Lust CDA34.003 C1.4 LTI Servo Drive
-
 LUST LTi Drives CM-CAN1 Communication Module
-
LUST LTi Motion CDB22.004 CDB2000 Drive
-
LUST Lti Drives CDE32.003 Frequency Drive
-
LTI VF1406M.C9.PT1.BR1 Frequency Drive
-
LUST LTI Drives CDA34.006 W3.0 Servo Drive
-
Lust LTI Drives CDA34.017.C2.CP Servo Controller
-
LTi DRiVES LST-097-5-30-560/T1 Servo Motor
-
LTi Drives LSH-050-2-45-320/T1 Servo Motor 4500rpm
-
 LUST LTI Drives VF1204S G10 FA VFD 0.75 kW 230VAC
-
LTi Drives LST-097-3-30-560/T1 1R Servo Motor
-
 LTI Servo One Junior SO22.003.0082.0000.0 Controller
-
LTI Drives GmbH SO22.003.0042.0000.0 Servo Controller
-
 LUST LTi CDB32.004.C2.4.SH Servo Drive 24-48V
-
LTi Drives LST-097-5-30-560/T1 1R Servo Motor
-
 LUST LTI Drives CM-CAN1 3084464 Communication Module
-
LUST LTi Drives CDE32.003.C2.3 Positioning Controller 230V


